AAMAS 2022

•

May 12, 2022

•

New Zealand

Please log in to leave a comment

Downloads

PaperTranscript English (automatic)

Next from AAMAS 2022

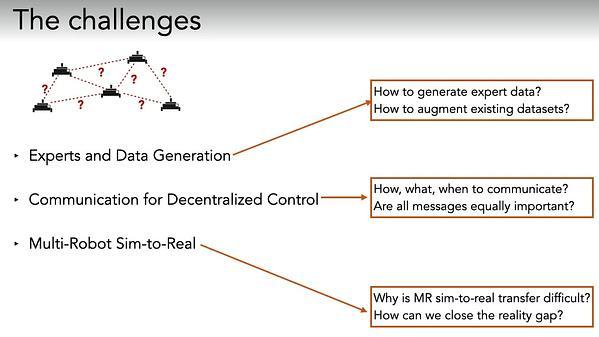
The Holy Grail of Multi-Robot Planning: Learning to Generate Online-Scalable Solutions from Offline-Optimal Experts
technical paper

The Holy Grail of Multi-Robot Planning: Learning to Generate Online-Scalable Solutions from Offline-Optimal Experts

AAMAS 2022

Amanda Prorok
Amanda Prorok

12 May 2022

Similar lecture

How experts explain motion planner output: a preliminary user-study to inform the design of explainable planners
panel

How experts explain motion planner output: a preliminary user-study to inform the design of explainable planners

IEEE RO-MAN 2021

Martim Brandão
+2
Martim Brandão and 4 other authors

09 August 2021